 LYNXSPACE
Programme · Fixed-wing VTOL UAV
SHADOWLYNX
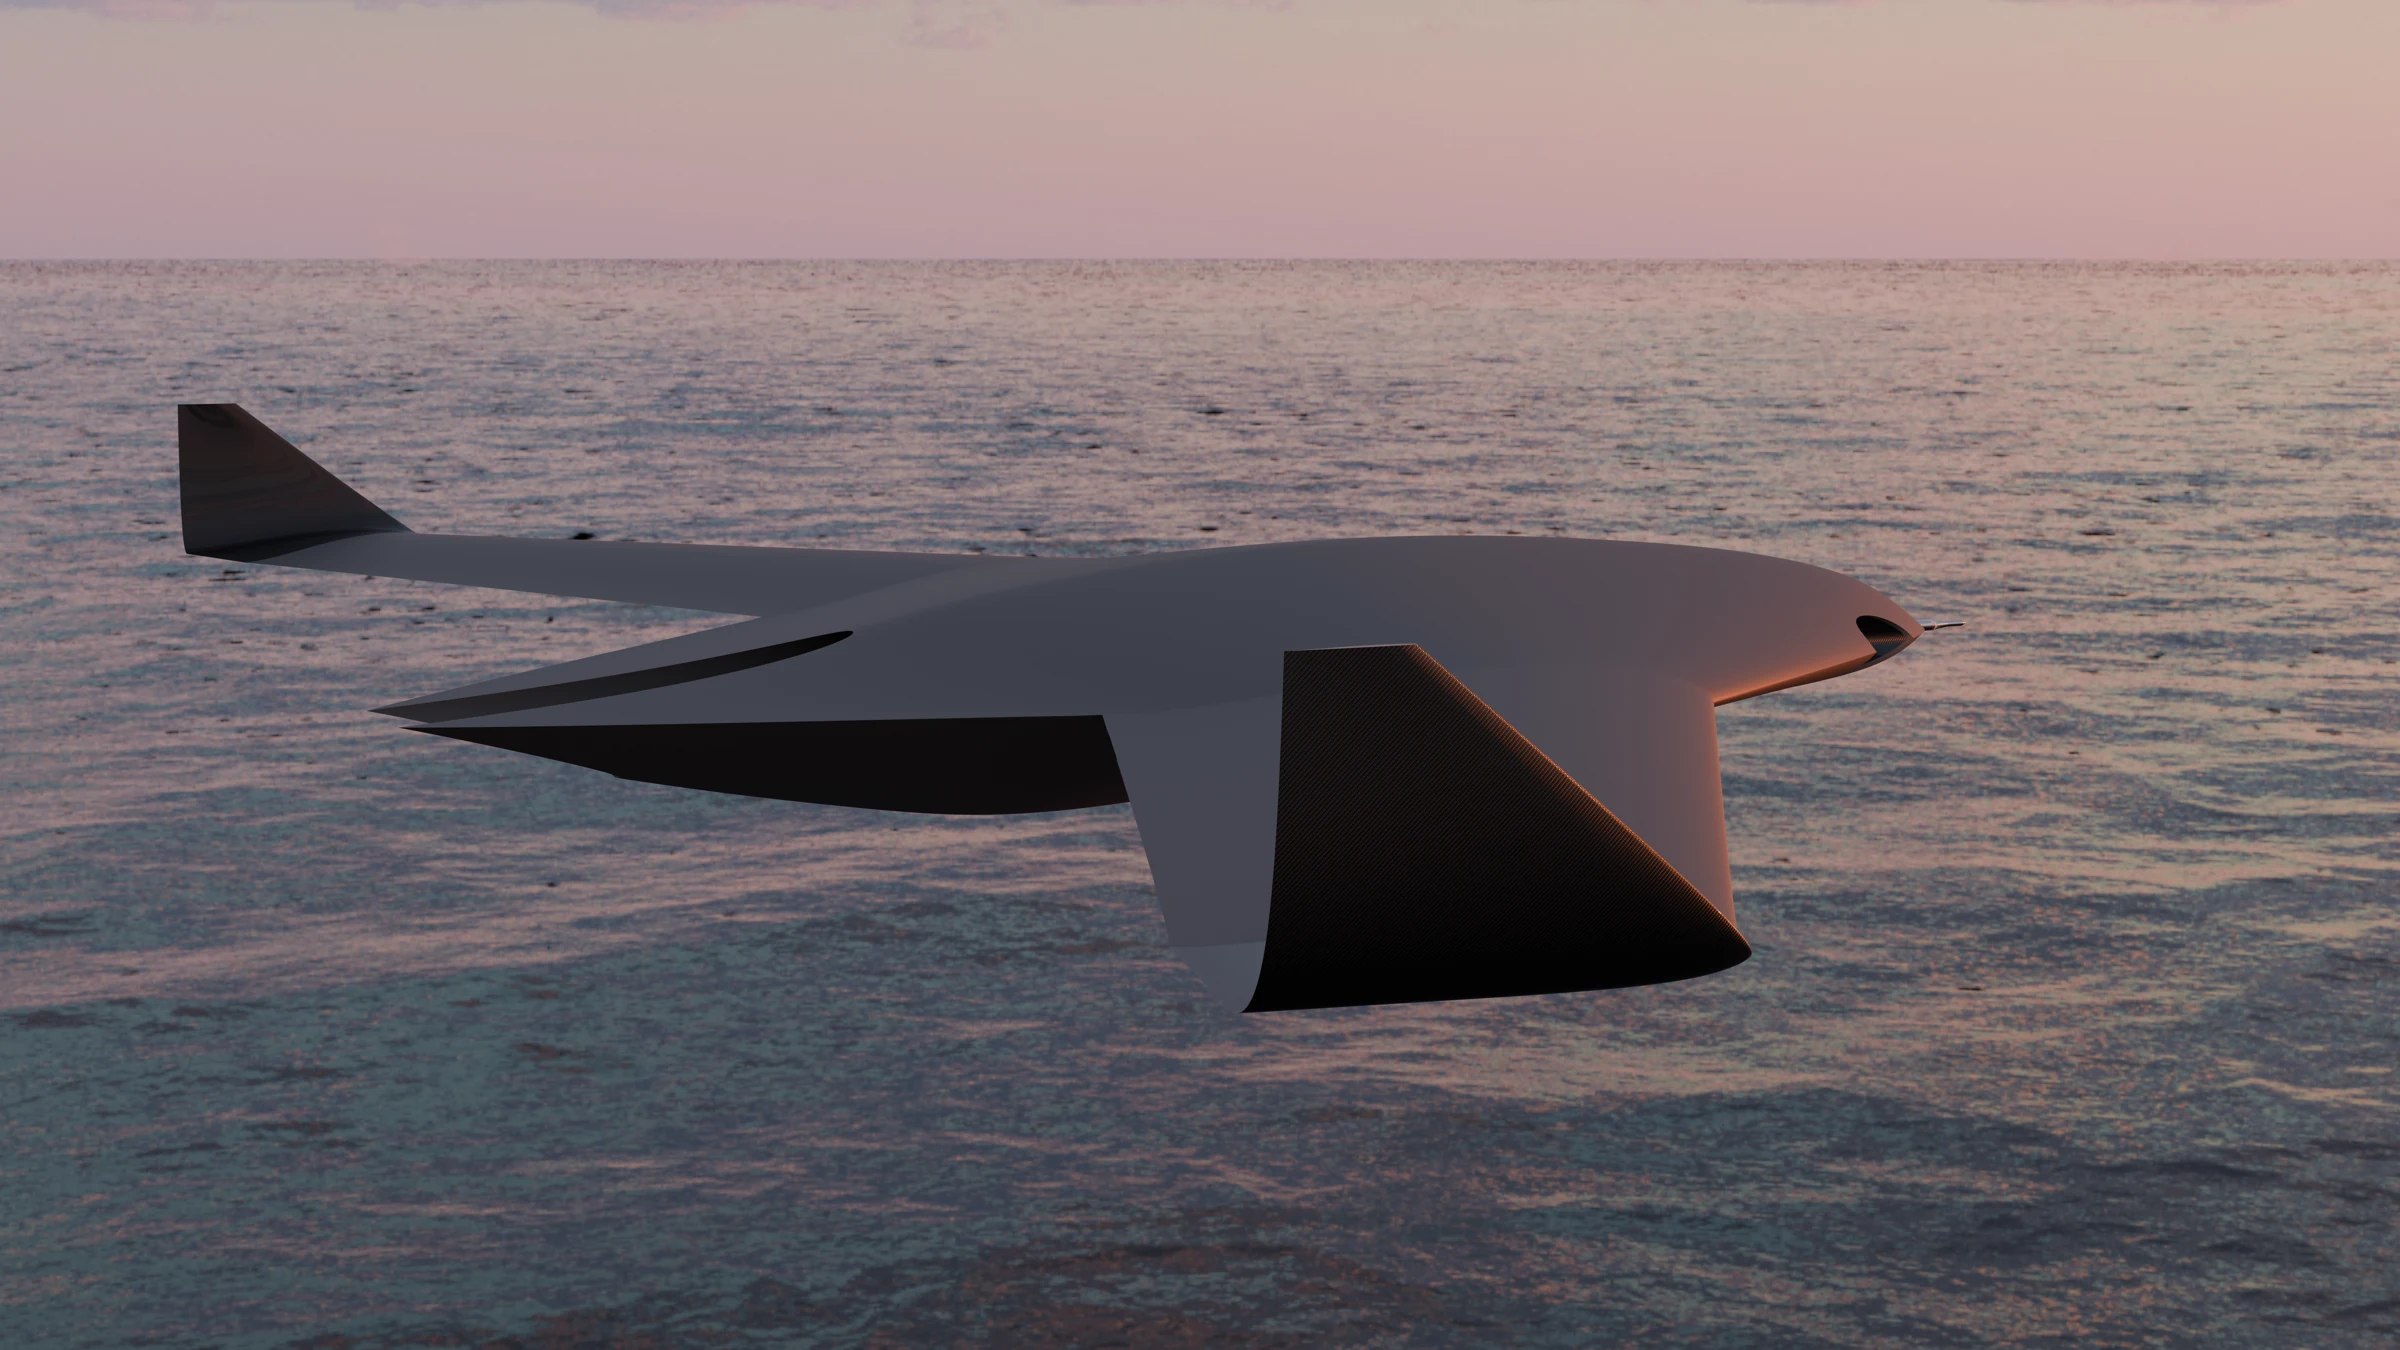
Fixed-wing VTOL platform designed for extended atmospheric data collection, aerial imaging and autonomous mission profiling over remote terrain.
| Class | Fixed-wing VTOL UAV |
|---|---|
| Airframe | Composite fibre |
| Guidance | Fully autonomous, no pilot required |
| Wingspan | 2.89 m (winglet tip to tip) |
| Endurance | 5+ h (target) |
| Stage | Pre-prototyping |
Programme
In development
ShadowLynx is in pre-prototyping, with a 2.89 m wingspan and a 1.69 m fuselage. The predicted maximum take-off weight is 20 kg. Speed, endurance and payload figures are design targets awaiting testing.
What is settled is the architecture: a fixed-wing airframe with vertical take-off and landing, a composite structure, and a guidance stack built on a custom flight controller with waypoint navigation, MagNav, geofencing and Starlink or line-of-sight communications. The aircraft is designed to fly completely autonomously, with AI reasoning integrated into that flight controller.
Mission
What it is designed to carry
The payload bay is interchangeable, so the sensor set is what decides the mission.
Design missions are atmospheric profiling, aerial imaging, search and rescue, defence and payload delivery, at low to medium altitude over extended mission windows. Communications use Starlink or a line-of-sight link, with a manoeuvring override from the ground station.
The bay is a hot-swap fitting: a gimbal-stabilised camera, an atmospheric package reading pressure, temperature, humidity, radiation and wind, or an experimental electronics payload. The target payload capacity is 10 kg. The sensor package will depend on the mission.
Reference sheet
ShadowLynx V1 specification
| Configuration | Fixed-wing VTOL |
|---|---|
| Material | Composite fibre |
| Wingspan | 2.89 m (winglet tip to tip) |
| Fuselage length | 1.69 m |
| MTOW | 20 kg (predicted) |
| Motor | 1 EDF; 2 optional open propellers for VTOL |
|---|---|
| Battery | Avionics: 6S; propulsion: not yet specified |
| Cruise speed | 110 km/h (target) |
| Max speed | 180 km/h (target) |
| Endurance | 5+ h (target) |
| Autopilot | Custom flight controller and firmware, with integrated AI reasoning |
|---|---|
| Navigation | Waypoints, MagNav, geofencing |
| GNSS | Multi-band |
| Telemetry | Starlink or line-of-sight link |
| Ground station | Line-of-sight manoeuvring override |
| Payload bay | Hot-swap, interchangeable |
|---|---|
| Imaging | 5 cameras; 4 optional positions for 1080p cameras, infrared cameras or LiDAR |
| Atmospheric | Pressure, temperature, humidity, radiation, wind |
| Payload capacity | 10 kg (target) |
| Video | 1080p or infrared options; Starlink or line-of-sight link |
Design specifications, subject to testing.
Development
Four steps to V2
Nothing on this timeline is complete. The first step is the one that produces hardware of any kind.
- 2026Next
Airframe validation
An EPP prototype to check wing geometry, the centre of gravity envelope and manual handling at low speed. Not the composite airframe: the first ShadowLynx of any kind.
- 2027Planned
Autopilot integration
Avionics testing for autonomous integration, with FPGA work alongside it.
- 2027Planned
Autonomous waypoints
A full automatic mission: GPS waypoints, MagNav validation, return to launch and geofence observation.
- 2028Planned
V2
Full systems integration, greater autonomy and research capability.
Contact
The airframe is not frozen
ShadowLynx is at the stage where a payload or a mission profile can still change the aircraft. If you need something specific measured, imaged or carried, the geometry is still open.